Finger links and joint supports
Identify pivot bores, pin fits, side clearance and the surfaces that locate each joint. Thin sections and small internal radii affect tool access and workholding.
APPLICATION EXAMPLE · ROBOTICS
Finger links, joint supports and mounting interfaces for articulated robot hands. Review the component geometry, pivot relationships and assembly clearances before selecting the machining route.
Request a Quote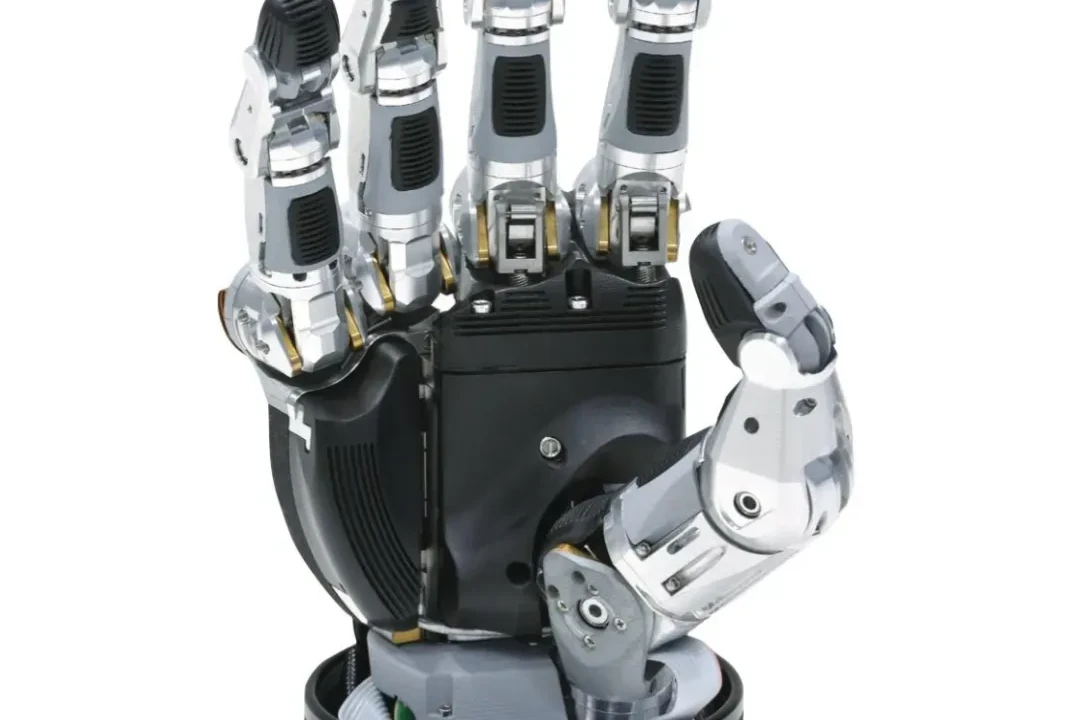
A robot hand combines several different structural parts. The pictured hand and separate joint components illustrate the application; they do not establish a material grade, machining method or delivered TOVILON project.
Identify pivot bores, pin fits, side clearance and the surfaces that locate each joint. Thin sections and small internal radii affect tool access and workholding.
Review the actual palm model separately. Finger mounting positions, actuator space and the wrist connection must match the complete assembly.
Check space for tendons, cables, fasteners or linkages through the required movement. A part that meets isolated dimensions can still interfere after assembly.
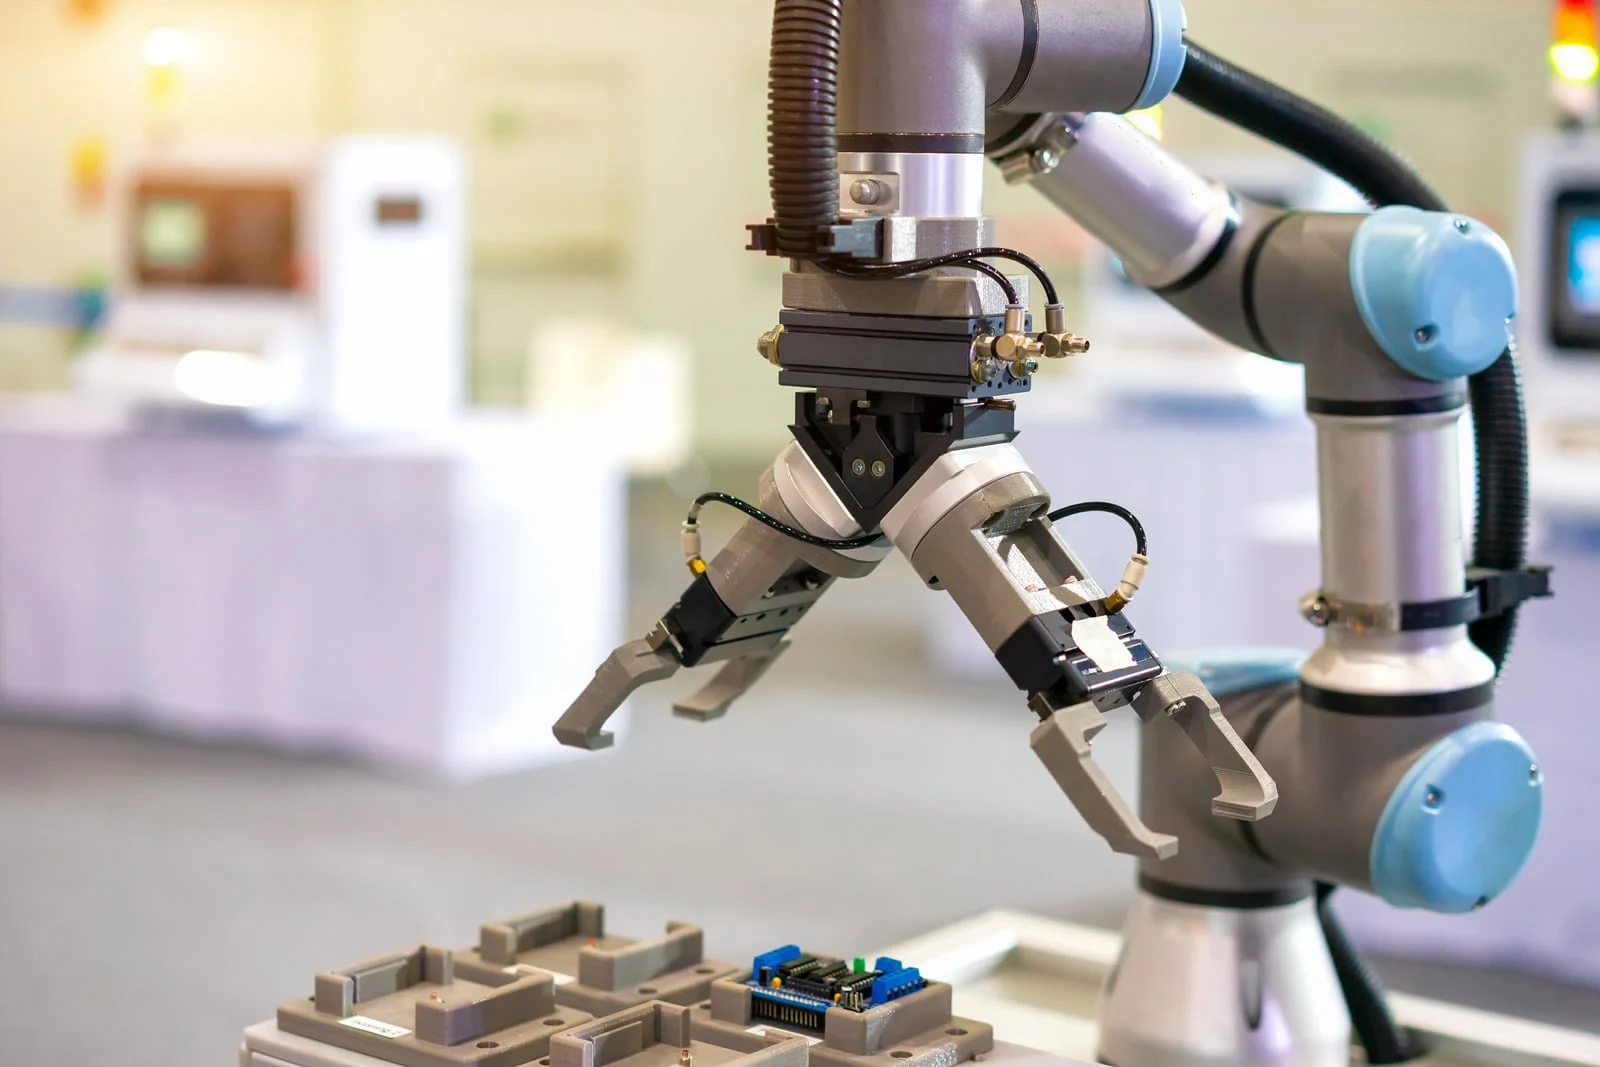
Indexed or simultaneous five-axis machining may help with angled features and contoured surfaces. Simpler links can use milling, while pins and bushings may use turning. The component model, material and required fit determine the route.
Agree how pivot position, bore size, mating faces and edge conditions will be measured. Material grade, achievable tolerances, surface treatment and inspection records are confirmed for the quoted component.
Five-axis machining reviewInclude the released model and drawing, material, quantity, mating pin or bearing information, movement envelope and the interfaces that determine acceptance. Use assembly views to explain clearance and routing requirements.
Explore other part applicationsSee also our robotics components.